I am Yan Ma, a Ph.D. student in Electronic Engineering at The Chinese University of Hong Kong (2023.01–2027.06, expected), advised by Prof. Hongliang Ren. I work on medical imaging robotics.
My research includes uncertainty-aware cross-scale hand-eye calibration of 2-D optical coherence tomography, continuum robots, and robot learning (imitation learning, reinforcement learning, and vision-language-action models such as π0.5). Selected papers appear in IEEE Transactions on Robotics and Nature Communications.
📝 Publications
🤖 Medical Imaging Robotics
Uncertainty-Aware Cross-Scale Hand-Eye Calibration of 2-D Optical Coherence Tomography Using a Plane Target
Yan Ma, Haitian Lyu, Jiewen Lai, Ruiyang Zhang, Wu Yuan, Hongliang Ren
IEEE Transactions on Robotics (T-RO), vol. 42, pp. 3105–3120, 2026
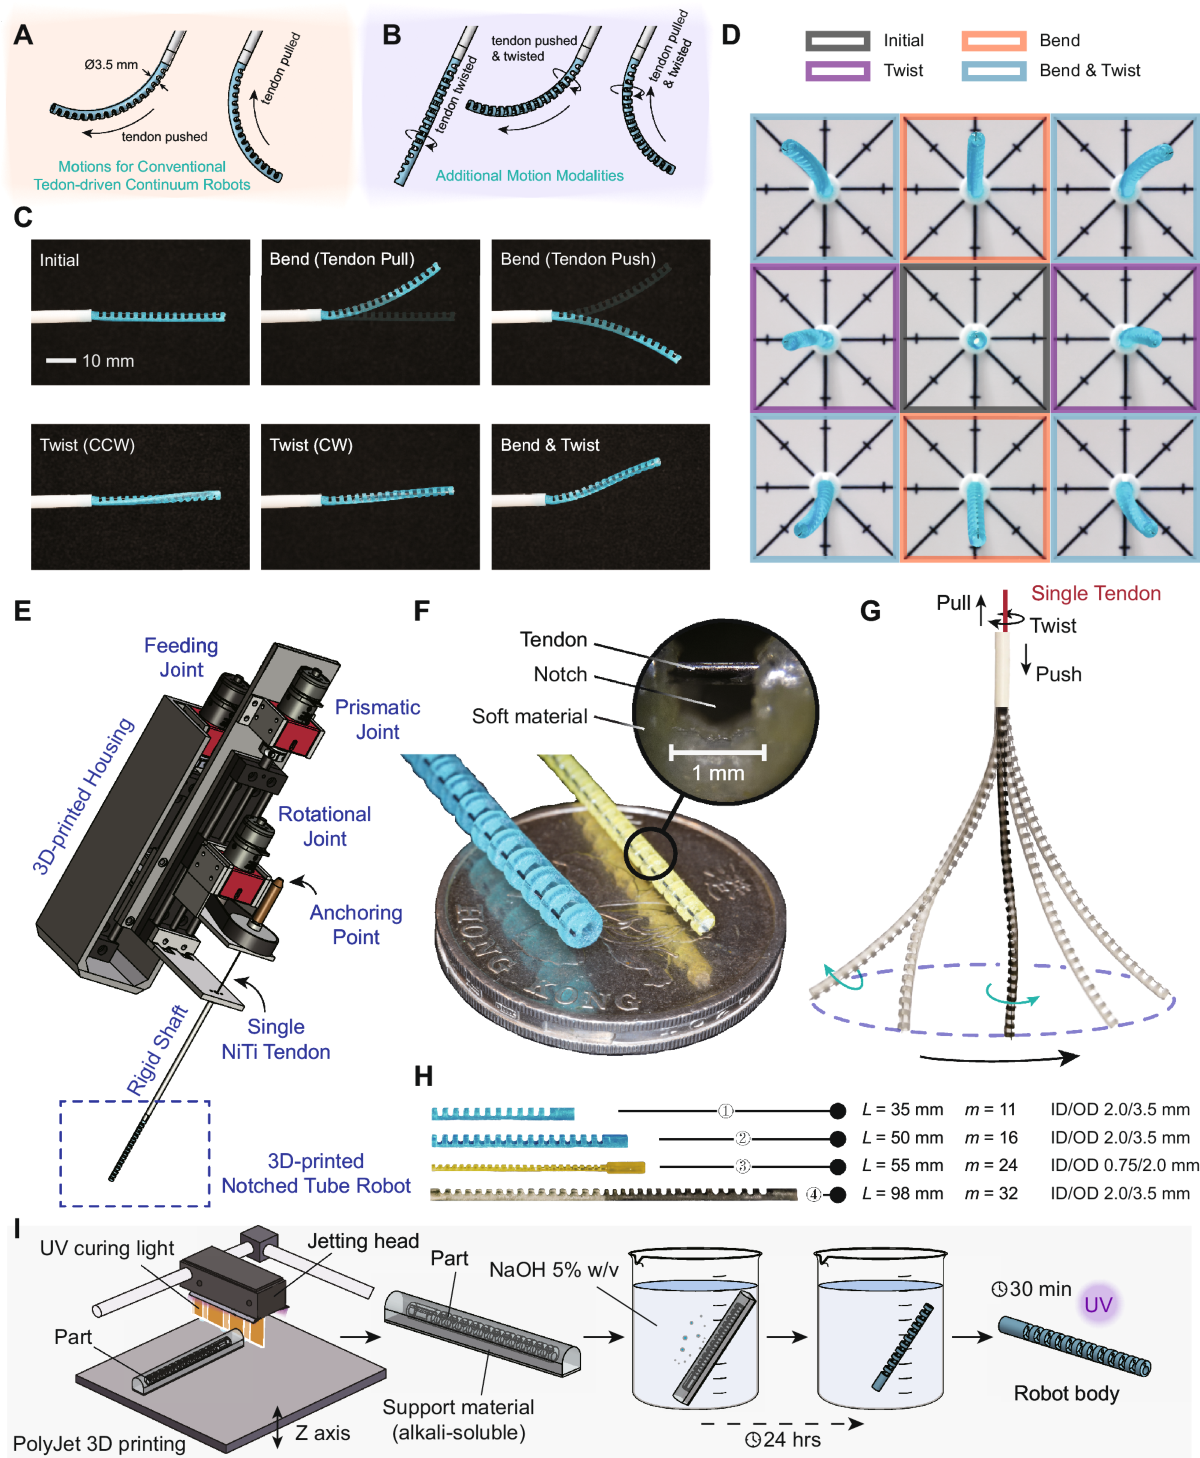
Single twistable tendon-driven continuum robots
Jiewen Lai, Yanjun Liu, Tian-Ao Ren, Yan Ma, Tao Zhang, Jeremy Yuen-Chun Teoh, Mark R. Cutkosky, Hongliang Ren
Nature Communications, vol. 17, art. no. 8322, 2026
Thumbnail: Fig. 1 of the paper, unchanged, CC BY 4.0.
A Wearable, Reconfigurable, and Modular Magnetic Tracking System for Wireless Capsule Robots
Shijian Su, Sishen Yuan, Zhen Li, Yan Ma, Miaomiao Ma, Hongliang Ren
IEEE Transactions on Industrial Informatics (TII), vol. 20, no. 12, pp. 13600–13611, 2024
Navigational Augmented Reality for Robotic Drilling
Yupeng Wang, Yan Ma, Hongliang Ren
IEEE International Conference on Advanced Robotics and Its Social Impacts (ARSO), pp. 86–91, 2024
🔬 Research
Multimodal skin inspection robot with OCT
2025.01 – present
A multimodal skin-inspection robot using optical coherence tomography (OCT). Hand-eye calibration is published in T-RO. The rest of the project covers ScanSim, ScanPlanner, and reinforcement-learning path planning.
VLA dual-arm
2026.07 – 2026.08
Vision-language-action dual-arm system using π0.5 and TRON2.
📖 Education
- 2023.01 – 2027.06 (expected), Ph.D., Electronic Engineering, The Chinese University of Hong Kong. Advisor: Prof. Hongliang Ren. Medical imaging robotics.
- 2018.09 – 2022.06, B.Eng., Mechanical Engineering, Shanghai Jiao Tong University. Top 10%.
🛠 Skills
- Robotics: imitation learning (ACT, Diffusion Policy, π-series); reinforcement learning (PPO, SAC); computational geometry
- Programming: Python, C++, MATLAB
- Software: ROS, PyTorch
- Hardware: robot arms, cameras, dexterous hands, motion capture
- Language: IELTS 7.5